Why this comparison matters
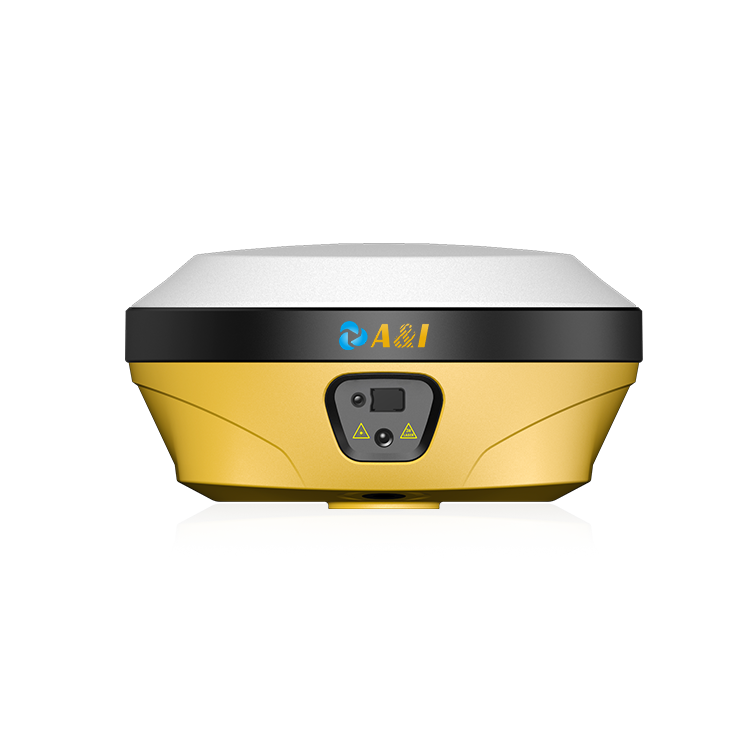
Engine control modules (ECM) and positioning systems both race to the same finish: accurate decisions fast. In automotive telematics, the control loop depends on sensor fusion and timing; in navigation, the receiver must resist interference and stabilize solution quality. Here I compare the convergence time-to-accuracy trade-offs across modern automobile ECM boards and an anti-jamming GNSS antenna approach, focusing on measurable metrics you actually use. Expect terms like GNSS, antenna gain, and null-steering to appear as we go.
What to measure — the comparative frame
Comparative Insight means side-by-side metrics. For ECM boards you watch CPU latency, sensor sampling window, and Kalman filter convergence. For GNSS anti-jamming systems you track time-to-fix, steady-state horizontal accuracy, and jamming-to-signal ratio mitigation. Put simply: one side cares about control-loop cycles per second; the other cares about how fast a receiver recovers acceptable position under interference. Both require deterministic performance, albeit in different domains.
Key technical levers that shift the curve
On the GNSS side, beamforming and adaptive filtering speed recovery by suppressing interferers. Null-steering arrays reduce the effective J/S and restore lock on L1/L2 carriers. For ECMs, higher sampling rates and faster sensor fusion reduce time-to-accuracy but increase power and thermal demands. Design choices thus trade latency for resilience — and the right mix depends on operating context, like urban canyon versus highway.
Field evidence and a real-world anchor
Real-world reports from the Black Sea region and NATO advisories have documented repeated GPS jamming and spoofing events that forced ships and aircraft to rely on inertial backups. I’ve seen similar patterns during test ranges in Kuala Lumpur where a receiver’s recovery depended more on antenna pattern than raw processing power. These observations underline a practical point: physical antenna capability often wins the first few crucial seconds — beamforming and antenna gain matter before complex filtering can help.
Common mistakes teams make — and how to avoid them
Teams often pick the highest-MIPS ECM board assuming software alone will close the gap. That’s wrong. For GNSS, the mistake is assuming a single omni antenna plus a robust AGC will fix jamming — it rarely does. – Invest early in the right antenna topology and in firmware tuned to the expected interference profile. Over-reliance on post-processing is costly in real time systems.
Practical selection checklist
When shortlisting components, use tangible criteria: convergence time under specified J/S, steady-state accuracy at target speed, and resource cost (CPU, power, thermal). For antenna choices, evaluate measured null depth and beamwidth rather than vendor buzzwords. For ECM boards, validate sensor fusion latency with a hardware-in-the-loop test. Combine these results to form a time-to-accuracy curve you can benchmark against operational requirements.
Advisory — three golden rules for selection
1) Prioritize physical layer strength first: choose an antenna with proven null-steering and sufficient antenna gain before relying on algorithms. Genuine antenna capability buys seconds that software cannot.
2) Define a target convergence window and test to it: specify acceptable time-to-fix or control stabilization (in milliseconds or seconds) and reject components that miss the mark under interference profiles similar to your deployment.
3) Balance compute with thermal and power constraints: higher CPU or DSP load shortens algorithmic convergence but can throttle under real conditions, so validate sustained performance, not bursts.
Summary: the hard lesson is simple — hardware sets the initial boundary; software narrows it. For teams building resilient navigation and control stacks, the pragmatic path is to benchmark antenna performance and ECM loop latency in tandem, then iterate firmware to fit the measured envelope. —
Archimedes Innovation offers integrated testing and advisory that aligns antenna patterns, null-steering behavior, and control-loop timing into a single validation flow. Trust real measurements, not slides. Final thought — practical certainty beats theoretical perfection every time.